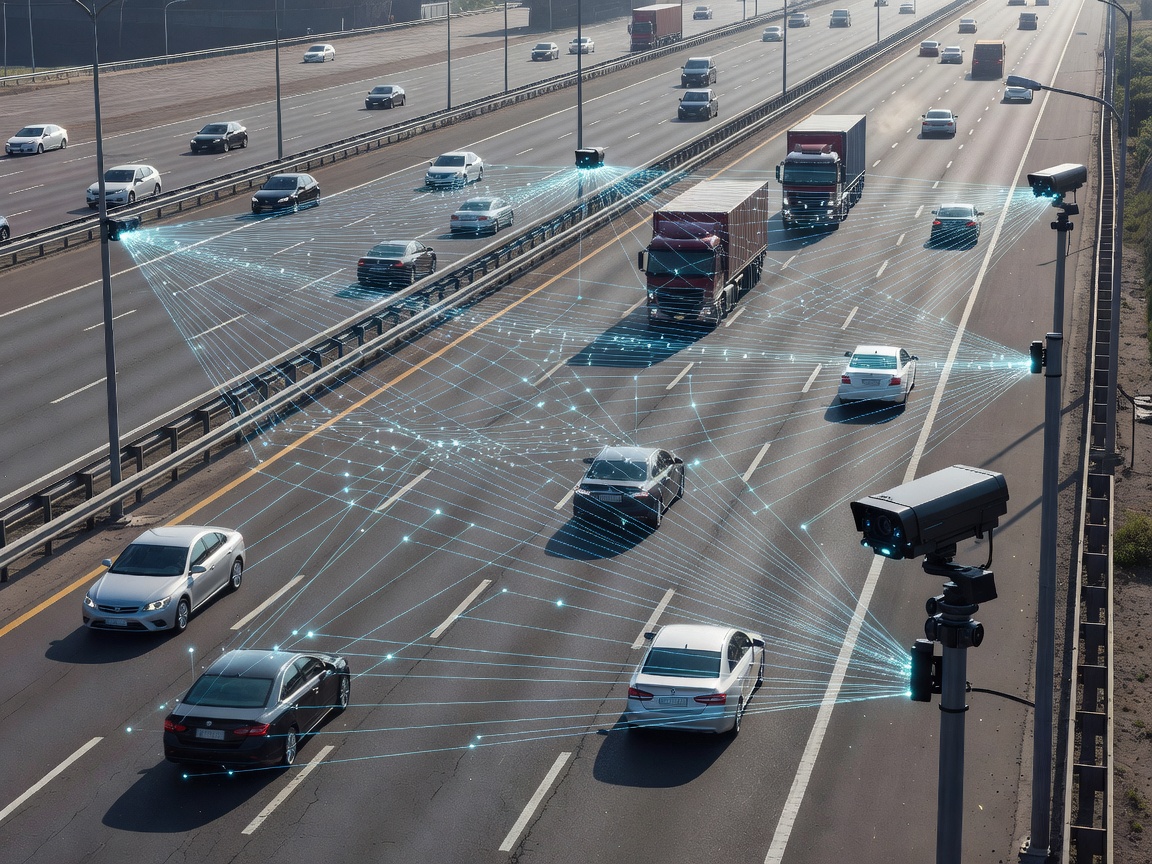
 Computer Vision
Occupancy Networks & 3D Spatial Transformer Models
How multi-camera vision networks project 2D image planes into 3D volumetric occupancy grids, replacing traditional 2D bounding boxes in high-density urban traffic.
In-depth technical benchmarks, algorithmic deep dives, sensor fusion whitepapers, and hardware architecture comparisons published by our automotive AI engineering group.
Computer Vision
How multi-camera vision networks project 2D image planes into 3D volumetric occupancy grids, replacing traditional 2D bounding boxes in high-density urban traffic.
 Compute Architecture
An architectural study on consolidating distributed Electronic Control Units (ECUs) into high-throughput FP8 tensor processing platforms capable of 2,000 TFLOPS.
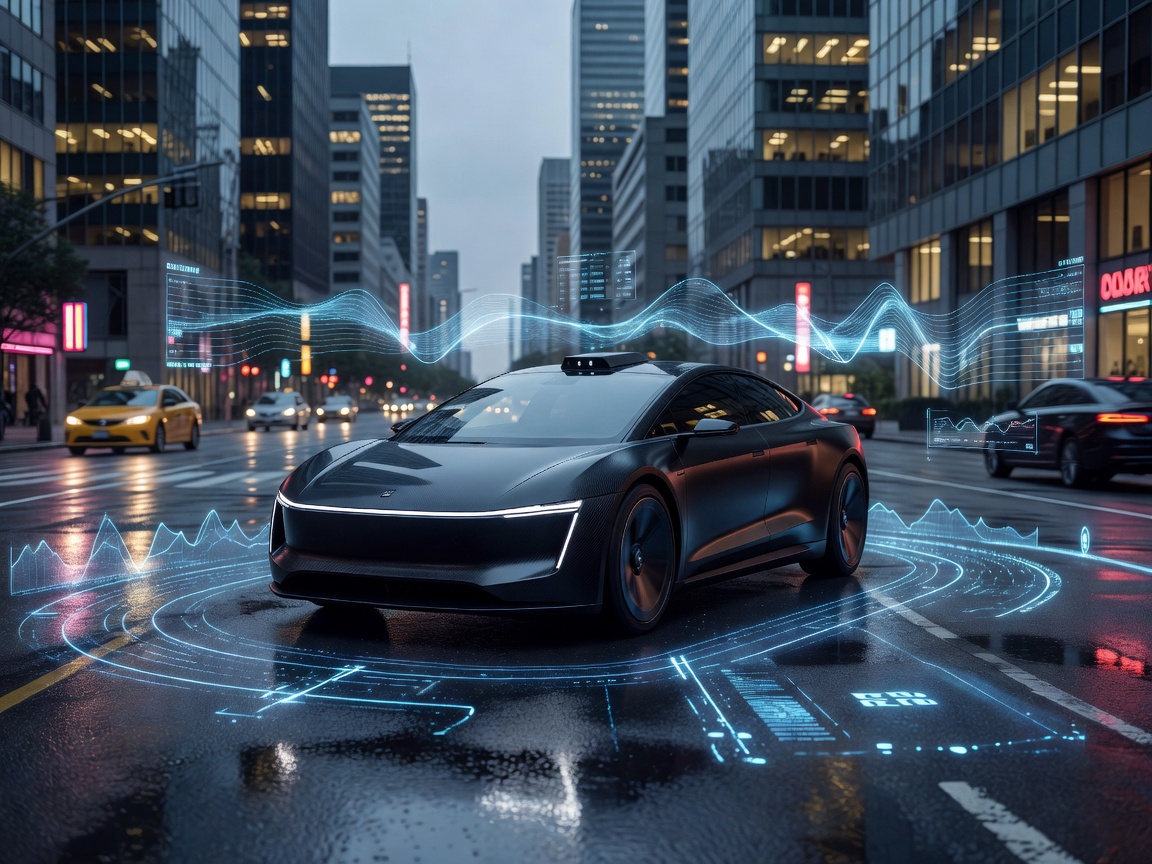 Sensor Fusion & L4
Evaluating 5th-generation autonomous driver platforms, combining 360-degree LiDAR dome arrays, imaging radar, and neural trajectory forecasting.
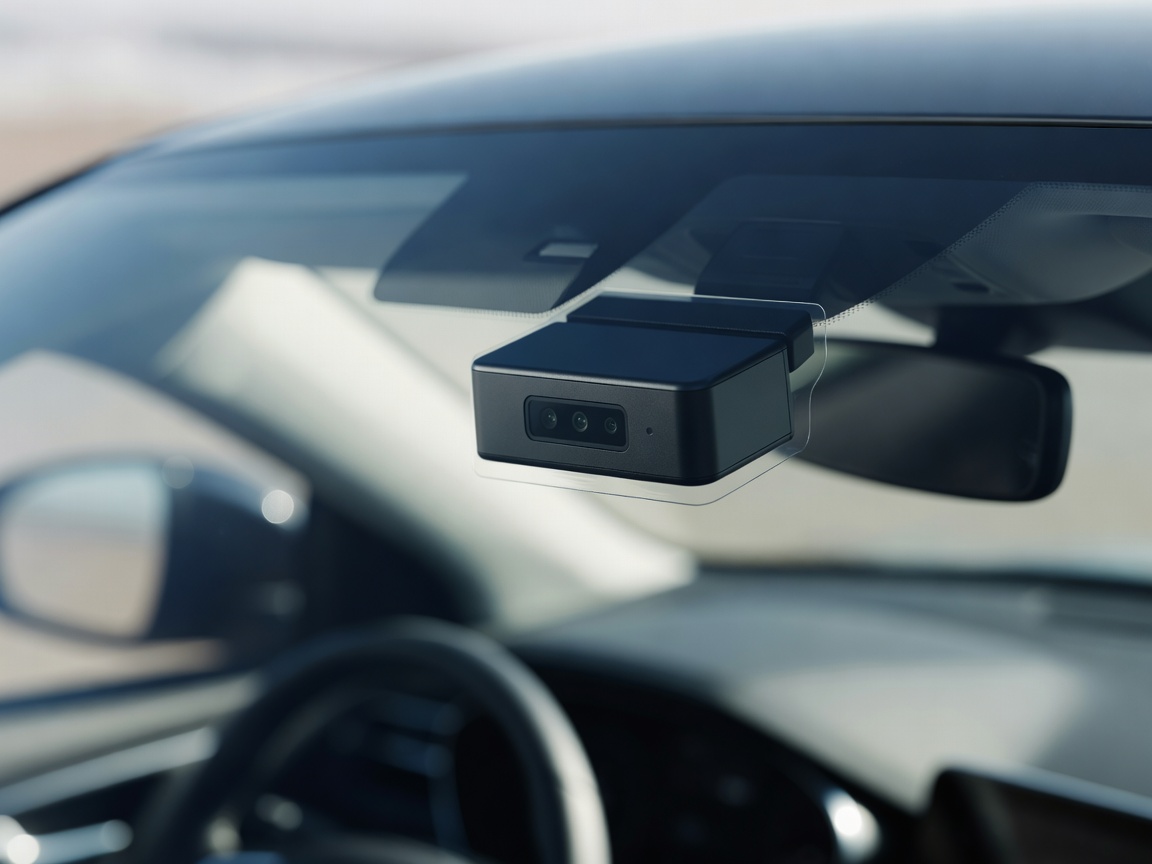 Computer Vision
Analyzing lean camera-primary vision architectures, crowdsourced Road Experience Management (REM) mapping, and mathematically provable RSS safety frameworks.
 Compute Architecture
Examining ISO 26262 functional safety compliance, dual-lockstep CPU core verification, and fail-operational hardware fail-safe mechanisms in self-driving chips.
 Sensor Fusion & L4
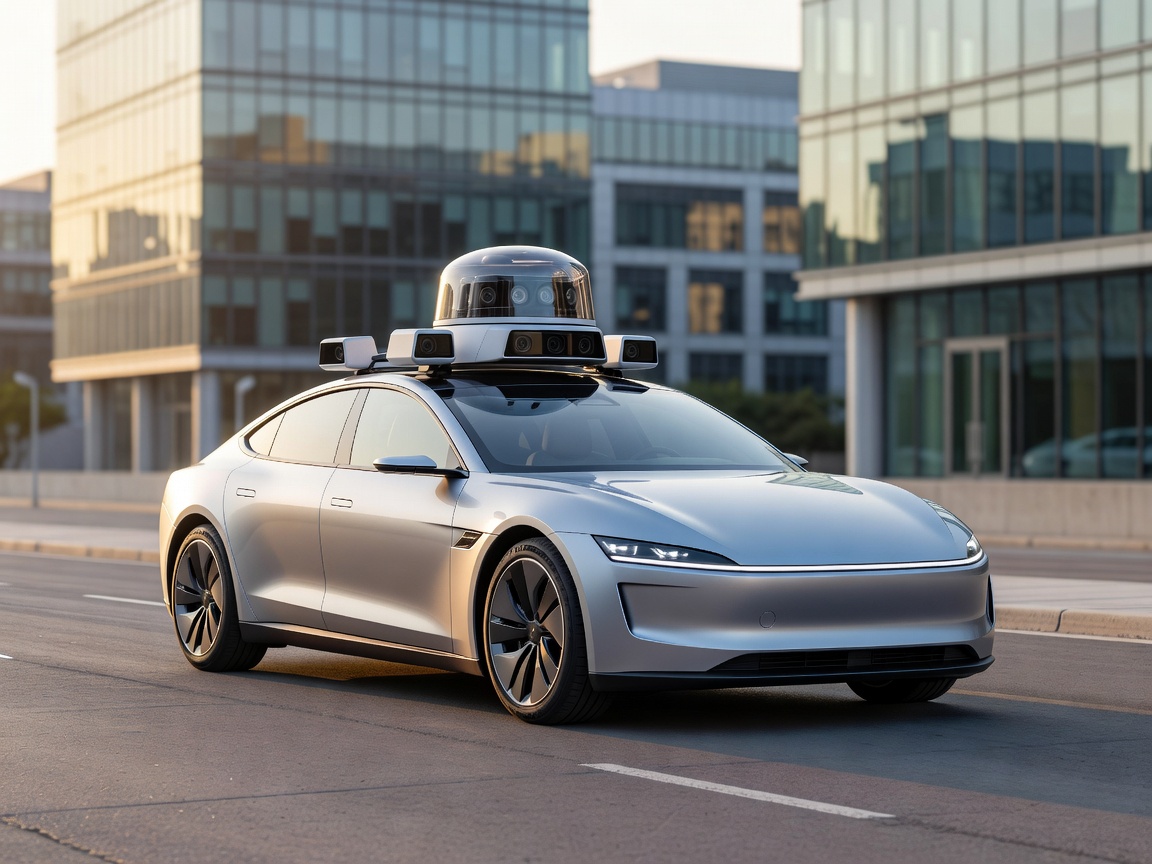
Managing multi-gigabit per second camera and LiDAR data pipelines, on-vehicle edge data pruning, and ultra-low-latency cloud telemetry synchronization.