The Data Ingestion Bottleneck
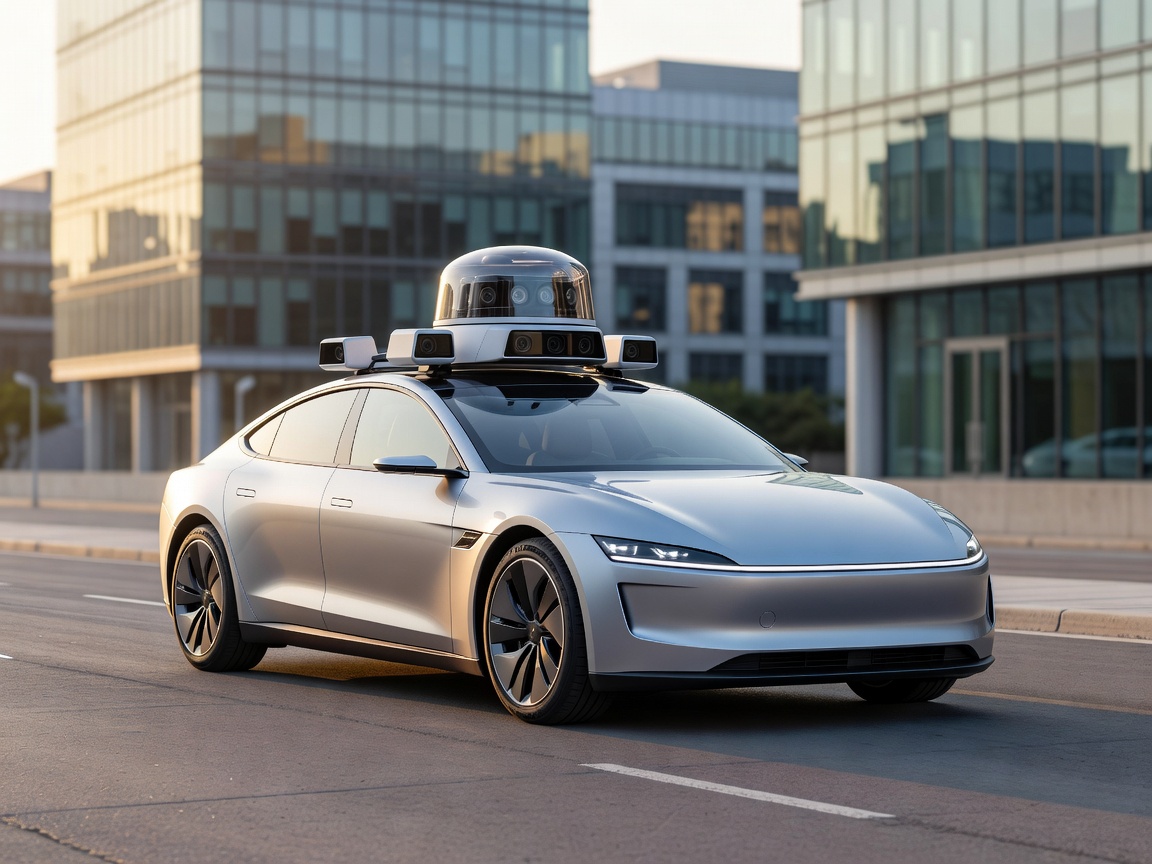
An autonomous vehicle equipped with 10 high-definition cameras, 4 LiDAR units, and 6 radar suites generates over 2 Terabytes of raw data per operational hour. Uploading complete raw logs over cellular 5G is economically infeasible and bandwidth-prohibitive.
Edge Telemetry Filtering Strategy
- Shadow Mode Execution: Running new neural models in background execution alongside active drivers to compute delta predictions.
- Trigger-Based Event Logging: Hard braking, unexpected disengagements, or low-confidence perception triggers immediate 10-second buffer retention.
- Compression & Vectorization: Converting raw point clouds into lightweight vector feature maps before transmission.
Automated Data Shadow Pipelines
By extracting active corner-case scenarios directly at the edge, engineering teams curate targeted training datasets to fine-tune perception models in continuous integration CI/CD loops.